Robohub.org
 

CoCoRo CeBIT


by
08 October 2014


share this:


CoCoRo CeBIT   YouTube

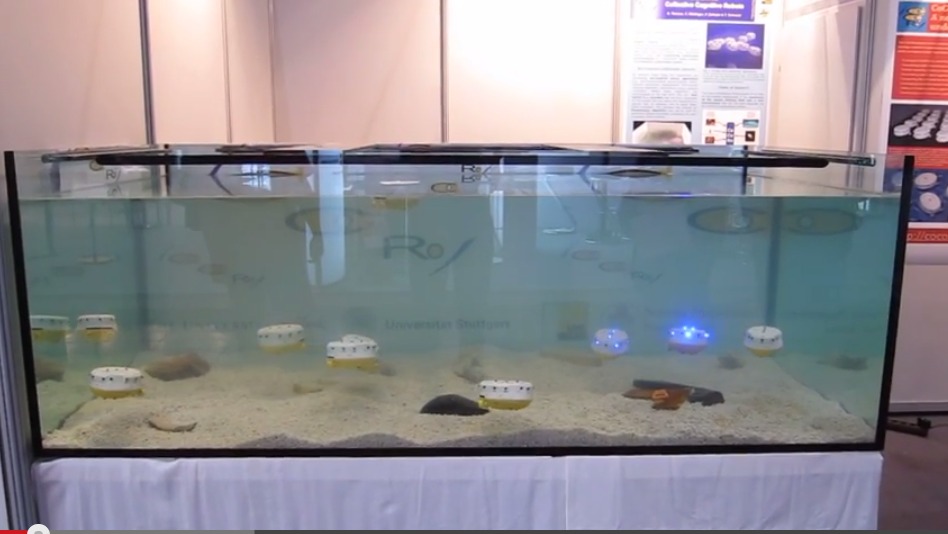
The EU-funded Collective Cognitive Robotics (CoCoRo) project has built a swarm of 41 autonomous underwater vehicles (AUVs) that show collective cognition. Throughout 2015 – The Year of CoCoRo – we will be uploading a new weekly video detailing the latest stage in its development. This video shows the CoCoRo autonomous underwater vehicles (AUVs) in a large aquarium at the CeBIT exhibition, and simulates a real mission scenario in which the AUVs have to collectively find an object of potential interest at the sea floor (e.g., a black box of a crashed plane).

In the beginning the AUVs start randomly distributed in the mission area (= aquarium) where the object is assumed to be. The AUVs do not perform a special search pattern but instead use a simple random walk. Due to the high number of AUVs, quite soon one of the AUVs will be near the object (in this case a magnetic target) and can perceive it.

The AUV then tries to keep its position above the object and starts to emit blue-light signals that attract other nearby AUVs which in turn also emit blue-light signals. This leads to a fast aggregation of most of the swarm AUVs near the object. In future underwater swarms these AUVs could then collectively grab and lift the object to the water surface.

To learn more about the project, see this introductory post, or check out all the videos from the Year of CoCoRo on Robohub.


tags: , , , , , , ,


Thomas Schmickl is an Associate Professor at Karl-Franzens University, Graz, Austria, and a lecturer at the University for Applied Sciences in St. Pölten, Austria.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence