
Robohub.org
 

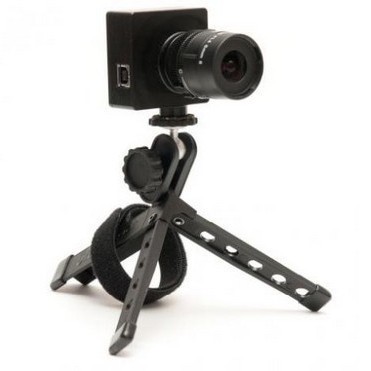
Low-latency event-based visual odometry | ETHZ via Phys.org

by
29 May 2014


share this:

One of the reasons we don’t yet have self-driving cars and mini-helicopters delivering online purchases is that autonomous vehicles tend not to perform well under pressure. A system that can flawlessly parallel park at 5 mph may have trouble avoiding obstacles at 35 mph.

John Payne‘s insight:

From http://rpg.ifi.uzh.ch/docs/ICRA14_Censi.pdf

“The achievable agility of a robotic platform depends on the speed of its processing pipeline (the series of data acquisition plus data processing); more precisely, it is important that the pipeline offers high sampling rate as well as low latency. At the state of the art, the latency of a CMOS-based pipeline is at a minimum in the order of 50- 250 ms and the sampling rate is in the order of 15-30 Hz. To obtain more agile robots, we need to switch to faster sensors.”

See on phys.org


John Payne

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 168 – Advancing robotics with novel electronics, with Zlatka Stoeva

  30 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Zlatka Stoeva from DZP Technologies about flexible, stretchable and soft printed electronics for dexterous robots.

Competing in RoboCup@Home and winning the 2026 best paper award: an interview with Raphael Memmesheimer

and   28 Oct 2026
Hear more about Raphael's research and his involvement in the RoboCup@Home league.

Robots in Society, Business and Culture: September 2026

We showcase a selection of robotics stories from society, business, research and culture.

Robot Talk Episode 167 – Automating construction, with Jan Petrš

  23 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Jan Petrš from École Polytechnique Fédérale de Lausanne about novel robot designs for construction and architecture.

ACM SIGAI Autonomous Agents Award 2027 open for nominations

  20 Oct 2026
Nominations are solicited for the 2027 ACM SIGAI Autonomous Agents Research Award.

Powered by muscle cells, a paper-thin robot swims through watery maze

  19 Oct 2026
MIT engineers’ new aquabot offers a way to design small, efficient “biohybrid” robots.

Robot Talk Episode 166 – Evolving robot bodies and brains, with Rika Antonova

  16 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Rika Antonova from the University of Cambridge about using artificial intelligence to develop complimentary robot hardware and algorithms.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence










