Robohub.org
ep.

068

podcast
 

Multi-robot teams with Vijay Kumar and Daniel Mellinger

GRASP Lab         

by
31 December 2010


share this:

Happy New Year from the whole Robots Podcast team! Don’t miss our amazing holiday robot videos!

For this last episode of 2010 we look at multi-robot teams and impressive quadrotor capabilities with Vijay Kumar from the GRASP Lab at the University of Pennsylvania and one of his PhD students, Daniel Mellinger.

Vijay Kumar
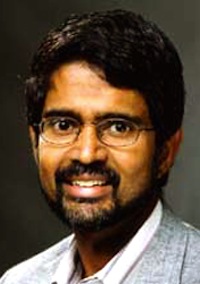
Vijay Kumar is Professor at the GRASP Lab and Associate Dean for Academic Affairs in the School of Engineering and Applied Science at UPenn.

As an expert in networked multi-agent systems, he’ll be telling us how he sees robot teams of tomorrow being deployed in real-world missions. Challenges include keeping the robots networked, selecting the right level of autonomy and figuring out how to deal with large swarms of heterogenous robots.

Among the robots he sees doing team work are flying robots including quadrotors that use SLAM to get around or that can perform impressive aggressive maneuvers.

Daniel Mellinger
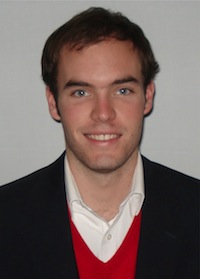
Daniel Mellinger is a PhD student at the GRASP Lab. He’s a rising star in dynamic control and has been featured in the media and on YouTube for his work with quadrotors passing through hoops and performing amazing motions.

We also speak about his latest work on transporting large objects using cooperative teams of quadrotors. This work got him the best paper award during the recent International Symposium on Distributed Autonomous Robotic Systems at EPFL.

Links:


Latest News:
For a review of 2010 in robotics, have a look at the Robots Forum!


tags: ,


Podcast team The ROBOTS Podcast brings you the latest news and views in robotics through its bi-weekly interviews with leaders in the field.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence