Robohub.org
ep.

049

podcast
 

URBI software platform with Jean-Christophe Baillie

Gostai         

by
09 April 2010


share this:

In this episode we look at robotics software platforms with Jean-Christophe Baillie who is the CEO of Gostai, a robotics software company out of Paris.

He tells us about the software URBI that he created to help developers program and control robots and his motivation to go open source at the International Conference on Robotics and Automation (ICRA) in a couple of weeks.

Jean-Christophe Baillie
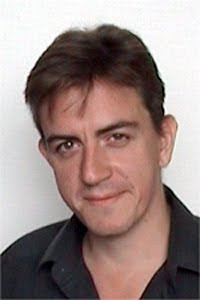
Jean-Christophe Baillie received a PhD in Artificial Intelligence from University of Paris 6 and Sony Computer Science Lab and then founded the Cognitive Robotics Lab in ENSTA/ParisTech.

He tells us about his past work on developmental robotics and more specifically on the Talking Heads experiments covered in part in an interview with Talking Robots. During this research, he designed URBI to control complex robotics systems like the AIBO. In 2006 Baillie founded Gostai to further develop the URBI technology which has now been extended to many robotic platforms such as the Nao humanoid used for the RoboCup robotics competition. He also tells us about his plans to make URBI open source and what that entails in terms of business model.


Latest News:

For videos of the current autonomous Audi TTS rally car prototype, details on NASA’s new autonomous exploration system AEGIS, and videos of Ishiguro’s new android, Geminoid F, have a look at the Robots Forum.

View and post comments on this episode in the forum


tags:


Podcast team The ROBOTS Podcast brings you the latest news and views in robotics through its bi-weekly interviews with leaders in the field.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence