
Robohub.org
ep.

312

podcast
 

Safe Motion Planning in Real-time with Luca Colasanto

by
19 June 2020


share this:


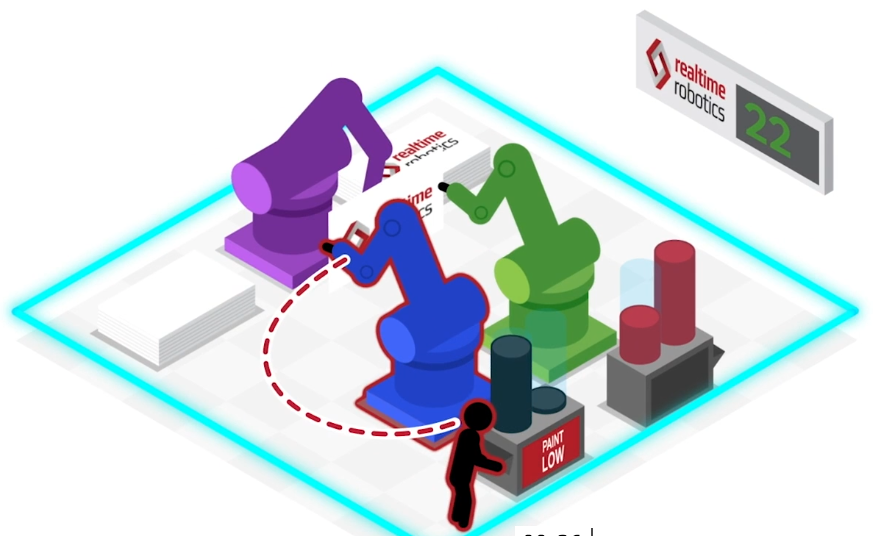
In this episode, we hear from Luca Colasanto, Senior Robotic Scientist at Realtime Robotics, about real-time robot motion planning in dynamic and complex environments with human-robot collaboration. Realtime Robotics focuses on accelerating conventional motion planning through optimization of algorithms and hardware to allow safe use of robotic tools in work areas with humans. Luca spoke to our interviewer Kate about Realtime Robotic’s fast motion planning technology, including key aspects, such as perception, algorithms and custom hardware.

Luca Colasanto
Luca Colasanto is a Sr. Scientist at Realtime Robotics focusing on AI-based grasping and multi-robot optimization. Luca completed his PhD in Humanoid Robotics at Italian Institute of Technology, focusing on control systems for bipedal walking machines and compliant actuators. During the past ten years, Luca has worked with successful startups to design and prototype new robotics products, and with science and technology leaders, such as Robert Bosch LLC (CA), Institute for Human and Machine Cognition (FL), and École Polytechnique Fédérale de Lausanne (Switzerland), He is the listed inventor in two patent applications and the author of several scientific publications. Luca speaks four languages and is a keen traveler, having visited or lived in more than 20 countries.

Links


tags: , , , ,


Kate Zhou

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 171 – Programming robot behaviour, with Sebastian Castro

  20 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Sebastian Castro about developing open-source software for robot task planning and behaviour.

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence










