Robohub.org
 

Driving, flying, and climbing in a sand and gravel pit

by
18 July 2016


share this:
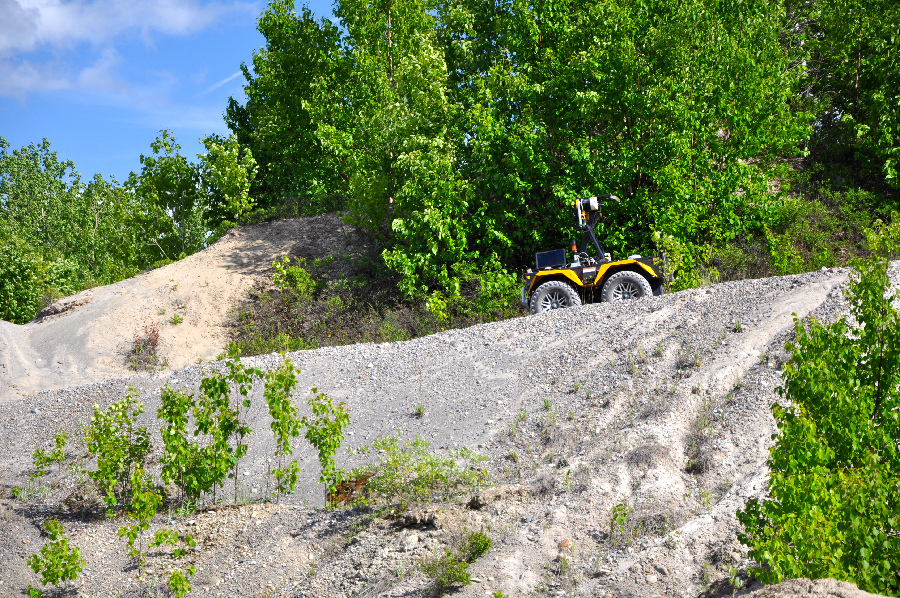
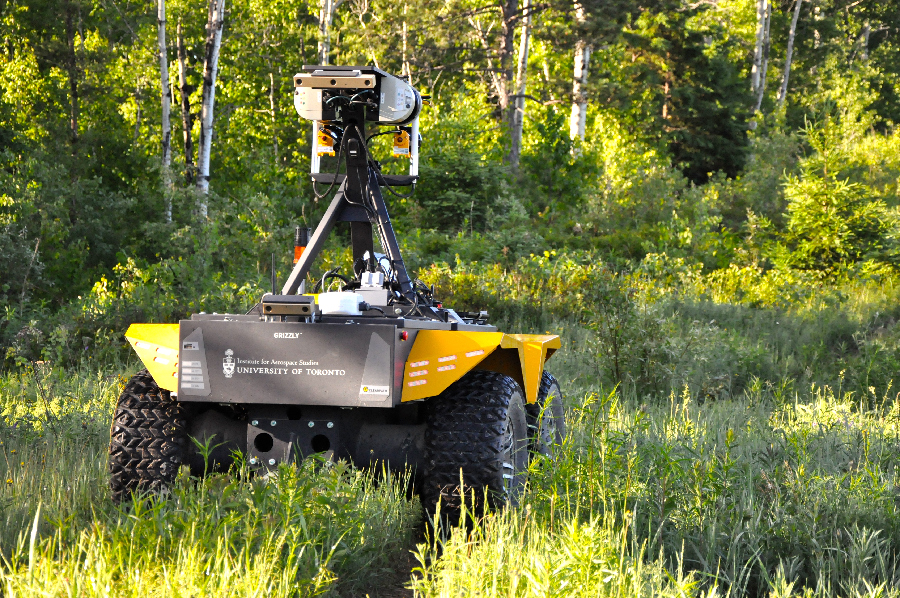
NCFRN Field Trials 2016. Photo: Tim Barfoot

NCFRN Field Trials 2016. Grizzly in challenging lighting. Photo: Tim Barfoot

In June, the University of Toronto (as part of the NSERC Canadian Field Robotics Network) carried out a set of field trials at an old sand and gravel pit in Sudbury, Ontario, Canada. This involved three main experiments:

  1. A new version of our Visual Teach and Repeat (VT&R) approach to vision-only route following,
  2. Aerial surveys of the site using fixed-wing unmanned aerial vehicles, and
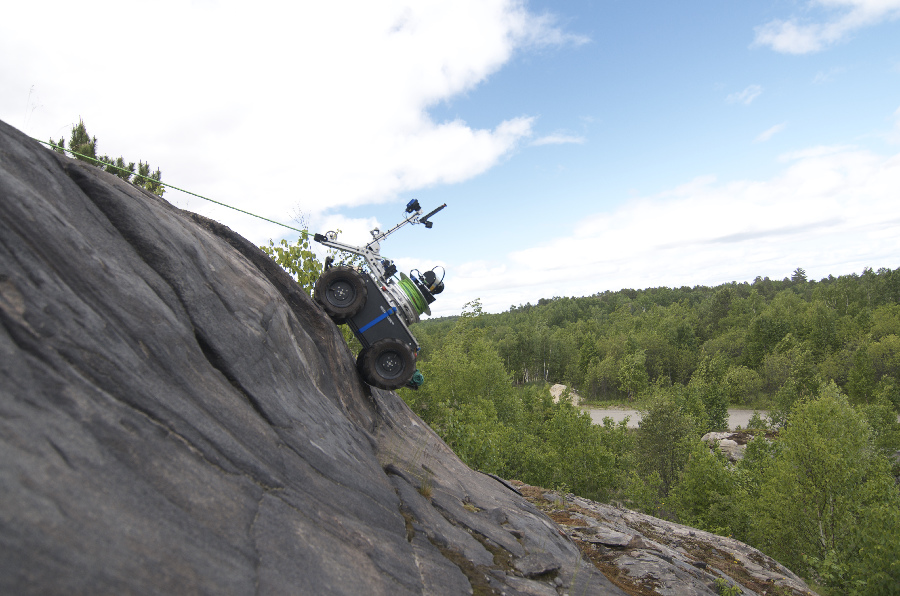
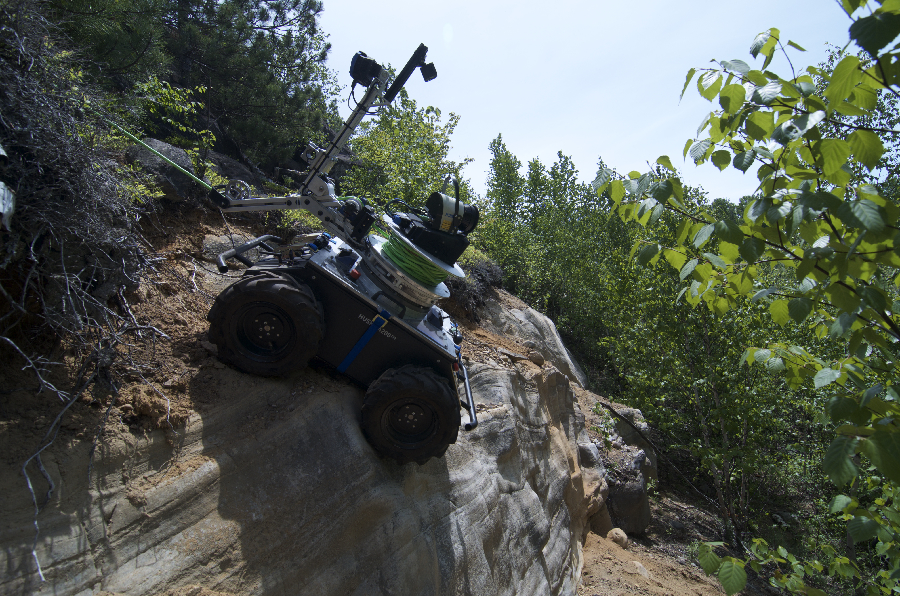
  3. A tethered robot design for mapping steep surfaces such as cliffs.

In the VT&R experiments, we taught our robot a 5 km network of interconnected paths, then carried out 120 km of autonomous repeats on these paths using only stereo vision for feedback. The below video shows some sections being repeated. Our new technique, dubbed VT&R 2.0, is a significant advance over our earlier work in that (i) it uses a Multi­-Experience Localization (MEL) technique to match live images to several previous experience of a path (making it more robust to appearance change), and (ii) is able to do place-­dependent terrain assessment to safeguard the robot and people around it, even in rough terrain with vegetation.

The team also captured some great images of the various experiments.  All images copyright Tim Barfoot or Francois Pomerleau.
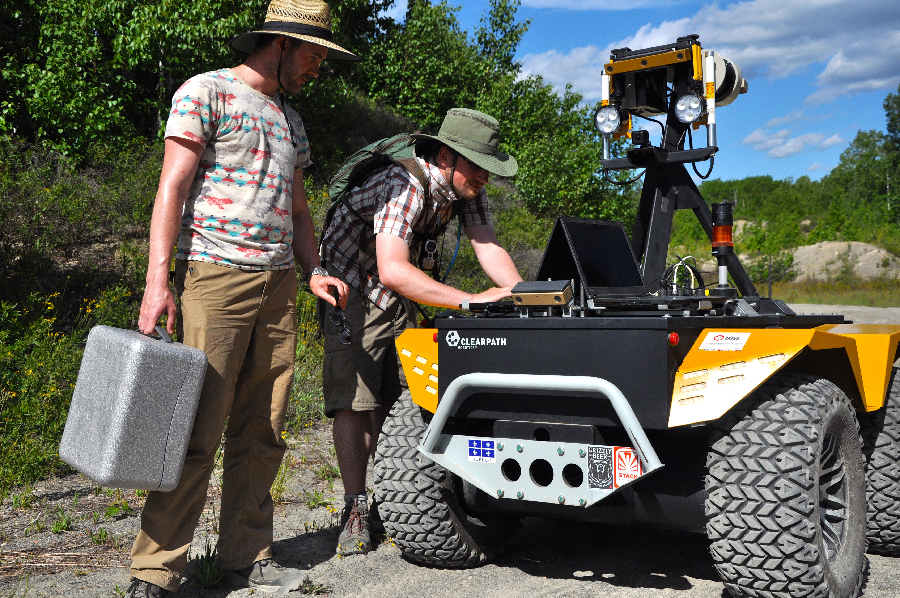
grizzly2 grizzly3 grizzly4 grizzly5

All photos can be viewed here.


This video is associated with the following papers:

Paton M, MacTavish K A, Warren M, and Barfoot T D. “Bridging the Appearance Gap: Multi-Experience Localization for Long-Term Visual Teach and Repeat”. In Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Daejeon, Korea, 9-14 October 2016

Berczi L P and Barfoot T D. “It’s Like Déjà Vu All Over Again: Learning Place-Dependent Terrain Assessment for Visual Teach and Repeat”. In Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Daejeon, Korea, 9-14 October 2016


tags:


Tim Barfoot Dr. Timothy Barfoot (Professor, University of Toronto Institute for Aerospace Studies -- UTIAS) holds the Canada Research Chair (Tier II) in Autonomous Space Robotics and works in the area of guidance, navigation, and control of mobile robots for space and terrestrial applications.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.

Robot Talk Episode 168 – Advancing robotics with novel electronics, with Zlatka Stoeva

  30 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Zlatka Stoeva from DZP Technologies about flexible, stretchable and soft printed electronics for dexterous robots.

Competing in RoboCup@Home and winning the 2026 best paper award: an interview with Raphael Memmesheimer

and   28 Oct 2026
Hear more about Raphael's research and his involvement in the RoboCup@Home league.

Robots in society, business and culture: September 2026

We showcase a selection of robotics stories from society, business, research and culture.

Robot Talk Episode 167 – Automating construction, with Jan Petrš

  23 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Jan Petrš from École Polytechnique Fédérale de Lausanne about novel robot designs for construction and architecture.

ACM SIGAI Autonomous Agents Award 2027 open for nominations

  20 Oct 2026
Nominations are solicited for the 2027 ACM SIGAI Autonomous Agents Research Award.

Powered by muscle cells, a paper-thin robot swims through watery maze

  19 Oct 2026
MIT engineers’ new aquabot offers a way to design small, efficient “biohybrid” robots.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence