Robohub.org
ep.

089

podcast
 

Demonstrations at IROS with Péter Fankhauser and Mike Rubenstein


by
21 October 2011


share this:

In today’s show, we hear about two demonstrations that caught our attention at the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Péter Fankhauser from the ETHZ in Zurich tells us about the Rezero ballbot, a balancing robot that speeds around on a sphere. Mike Rubenstein from the Self-organizing Systems Research Group at Harvard then tells us about their efforts to make swarms of 1024 robots a reality with the kilobot project.

Péter Fankhauser
© Karl Hug Ringier AG

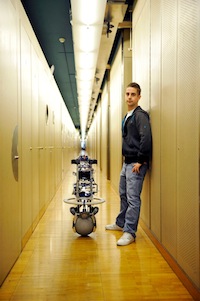
Péter Fankhauser is the leader of the Rezero ballbot project. The Rezero project was one of last year’s “Focus Projects” during which Bachelor students in Mechanical Engineering at ETHZ have the opportunity to develop a product from scratch. The project was supervised by Prof. Siegwart from the Autonomous Systems Laboratory. Rezero brought together eight future mechanical engineers, two electrical engineers studying at the ZHAW as well as Industrial Designers from ZHdK.

The interdisciplinary team developed the ballbot, a robot that balances and drives around on a ball. Using a single ball instead of wheels allows the robot to move spontaneously in any direction, fit into tight spaces, and achieve high speeds. The robot was often seen zipping through the hallways at IROS earlier this month.

Fankhauser tells us about his learning experience, challenges in working in large crossdisciplinary teams, the secret behind the ballbot capabilities and the future steps in making the ballbot a commercial reailty.


Mike Rubenstein
Mike Rubenstein is a postdoctoral researcher from the Self-organizing Systems Research Group at Harvard. In an effort to make large swarms of robots a reality, he’s been building 1024 coin-sized robots dubbed kilobots. Challenges include making the robots low-cost and easy to assemble, recharge, reprogram and control. The final system is made with only $14 worth of parts, takes 5 minutes to assemble and can be operated in less than a minute. The open source release of all the electronics and assembly documents is expected near the end of this year.

After bording a plane with 100+ robots, Rubenstein was able to demonstrate the system at IROS.

In the future, Rubenstein hopes to implement his thesis work on “Self-assembly and self-healing for robotic collectives” on the kilobots. An example of such a system is show in the video below.


Links:


tags: ,


Podcast team The ROBOTS Podcast brings you the latest news and views in robotics through its bi-weekly interviews with leaders in the field.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

ACM SIGAI Autonomous Agents Award 2027 open for nominations

  20 Oct 2026
Nominations are solicited for the 2027 ACM SIGAI Autonomous Agents Research Award.

Powered by muscle cells, a paper-thin robot swims through watery maze

  19 Oct 2026
MIT engineers’ new aquabot offers a way to design small, efficient “biohybrid” robots.

Robot Talk Episode 166 – Evolving robot bodies and brains, with Rika Antonova

  16 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Rika Antonova from the University of Cambridge about using artificial intelligence to develop complimentary robot hardware and algorithms.

Humanoid robots can sprint and box – but the real test is doing the laundry

  12 Oct 2026
No robot system can yet reliably handle the whole laundry process. Even folding remains a challenge.

Robot Talk Episode 165 – Robots behind the research, with Kushant Patel

  09 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Kushant Patel from Brookhaven National Laboratory about robots that work in scientific facilities, such as particle accelerators.

What three days building a robot taught me

and   07 Oct 2026
The brief sounded simple: build a small autonomous robot, then make it survive increasingly difficult mazes. Simple... right? Until you actually have to build one.

Research could guide the future design of social robots

  05 Oct 2026
Giving robot companions animal-like or anime-style faces and voices could maximise their emotional appeal to users, according to new research which could help guide the growing field of social robotics.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence