Robohub.org
 

Grasping unknown objects


by
06 May 2014


share this:

This post is part of our ongoing efforts to make the latest papers in robotics accessible to a general audience.

To manipulate objects, robots are often required to estimate their position and orientation in space. The robot will behave differently if it’s grasping a glass that is standing up, or one that has been tipped over. On the other hand, it shouldn’t make a difference if the robot is gripping two different glasses with similar poses. The challenge is to have robots learn how to grasp new objects, based on previous experience.
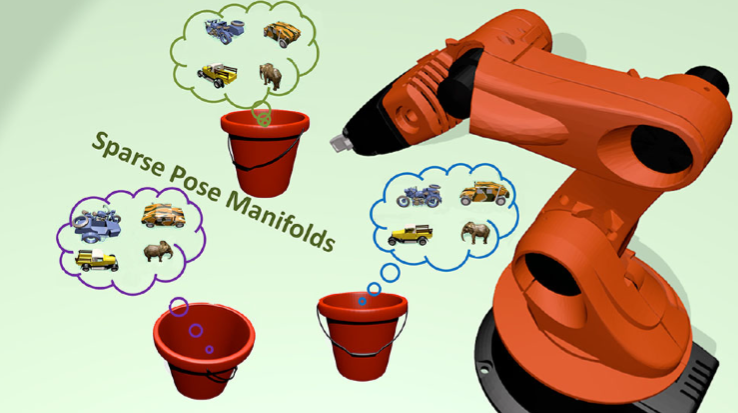
Bucket

To this end, the latest paper in Autonomous Robots proposes a Sparse Pose Manifolds (SPM) method. As shown in the figure above, different objects viewed from the same perspective should share identical poses. All the objects facing right are in the same “pose-bucket”, which is different from the bucket for objects facing left, or forward. For each pose, the robot knows how to behave to guide the gripper to grasp the object. To grip an unknown object, the robot estimates what “bucket” the object falls into.

The videos below shows how this method can efficiently guide a robotic gripper to grasp an unknown object and illustrates the performance of the pose estimation module.


tags: , ,


Autonomous Robots Blog Latest publications in the journal Autonomous Robots (Springer).

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

What three days building a robot taught me

and   07 Oct 2026
The brief sounded simple: build a small autonomous robot, then make it survive increasingly difficult mazes. Simple... right? Until you actually have to build one.

Research could guide the future design of social robots

  05 Oct 2026
Giving robot companions animal-like or anime-style faces and voices could maximise their emotional appeal to users, according to new research which could help guide the growing field of social robotics.

Robot Talk Episode 164 – Accelerating robot learning, with Michelle Lu

  02 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Michelle Lu from Vsim Technology about using simulation and artificial intelligence to teach robots new skills.

Robotics and automation? Informal reflections on familiar terms

IEEE experts reflect on what is meant by the term "robotics and automation".

Small, medium or large, a robotic fish maintains its swimming ability

  28 Sep 2026
Researchers at EPFL and New York University have developed a robotic fish that can be made in various sizes for studying shallow creeks to open water.

Robot Talk Episode 163 – Robots helping people, with Aaron Edsinger

  25 Sep 2026
In the first episode of Robot Talk season 7, Claire chatted to Aaron Edsinger from Hello Robot about their Stretch robots that can help people with mobility issues live more independently.

An open source approach to physical AI from Intrinsic

  25 Sep 2026
Find out more about the capabilities of Intrinsic Core.

What’s coming up at #IROS2026?

  24 Sep 2026
Find out what the International Conference on Intelligent Robots and Systems has in store.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence