Robohub.org
 

Air and ground robot collaborate to map and safely navigate unknown, changing terrain

by and
05 October 2015


share this:

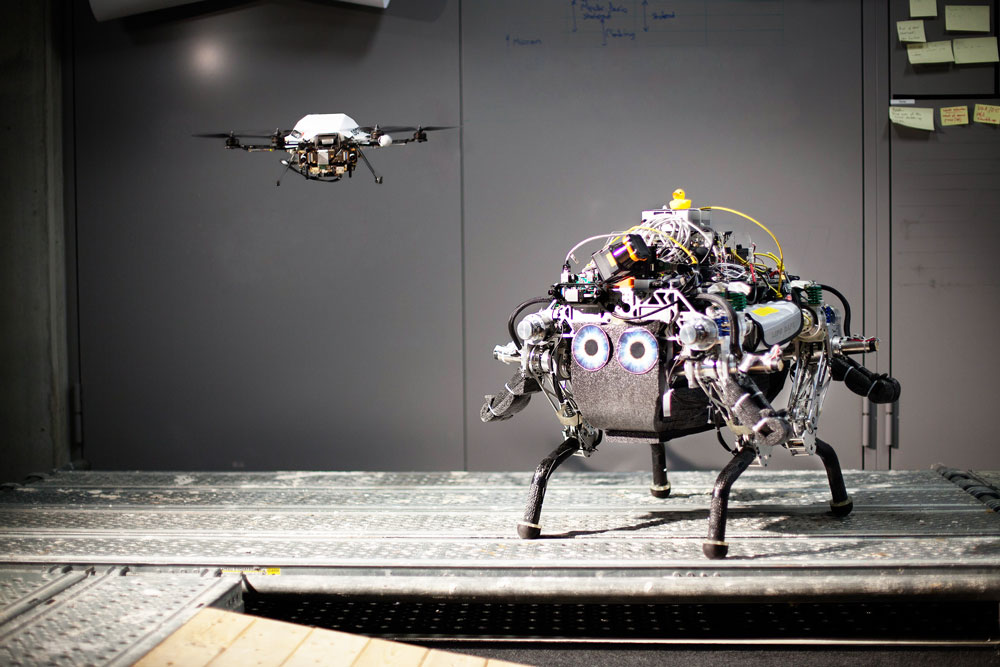
ASL_aerial_ground_robot_collaboration_ETHZThis video shows how a robot team can work together to map and navigate toward a goal in an unknown terrain that may change over time. Using an onboard monocular camera, a flying robot first scouts the area, creating both a map of visual features for simultaneous localization and a dense elevation map of the environment. A legged ground robot then localizes itself against the global map, and uses the elevation map to plan a traversable path to a goal.

While following the planned path, the absolute pose corrections are fused with the legged robot’s state estimation and the elevation map is continuously updated with distance measurements from an onboard laser range sensor. This allows the legged robot to safely navigate towards its goal while taking into account any changes in the environment.

More info: http://leggedrobotics.ethz.ch

This work was published as:
P. Fankhauser, M. Bloesch, P. Krüsi, R. Diethelm, M. Wermelinger, T. Schneider, M. Dymczyk, M. Hutter, and R. Siegwart, “Collaborative Navigation for Flying and Walking Robots,” in IEEE International Conference on Intelligent Robots and Systems (IROS), 2016.


tags: , , , , ,


Autonomous Systems Lab at ETH Zurich creates robots and intelligent systems that are able to autonomously operate in complex and diverse environments

Péter Fankhauser is a co-founder and Chief Business Development Officer at ANYbotics

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 167 – Automating construction, with Jan Petrš

  23 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Jan Petrš from École Polytechnique Fédérale de Lausanne about novel robot designs for construction and architecture.

ACM SIGAI Autonomous Agents Award 2027 open for nominations

  20 Oct 2026
Nominations are solicited for the 2027 ACM SIGAI Autonomous Agents Research Award.

Powered by muscle cells, a paper-thin robot swims through watery maze

  19 Oct 2026
MIT engineers’ new aquabot offers a way to design small, efficient “biohybrid” robots.

Robot Talk Episode 166 – Evolving robot bodies and brains, with Rika Antonova

  16 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Rika Antonova from the University of Cambridge about using artificial intelligence to develop complimentary robot hardware and algorithms.

Humanoid robots can sprint and box – but the real test is doing the laundry

  12 Oct 2026
No robot system can yet reliably handle the whole laundry process. Even folding remains a challenge.

Robot Talk Episode 165 – Robots behind the research, with Kushant Patel

  09 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Kushant Patel from Brookhaven National Laboratory about robots that work in scientific facilities, such as particle accelerators.

What three days building a robot taught me

and   07 Oct 2026
The brief sounded simple: build a small autonomous robot, then make it survive increasingly difficult mazes. Simple... right? Until you actually have to build one.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence