
Robohub.org
 

Gecko adhesives allow flying robot to perch on walls

by
15 May 2013


share this:
AirBurrXwithLegs

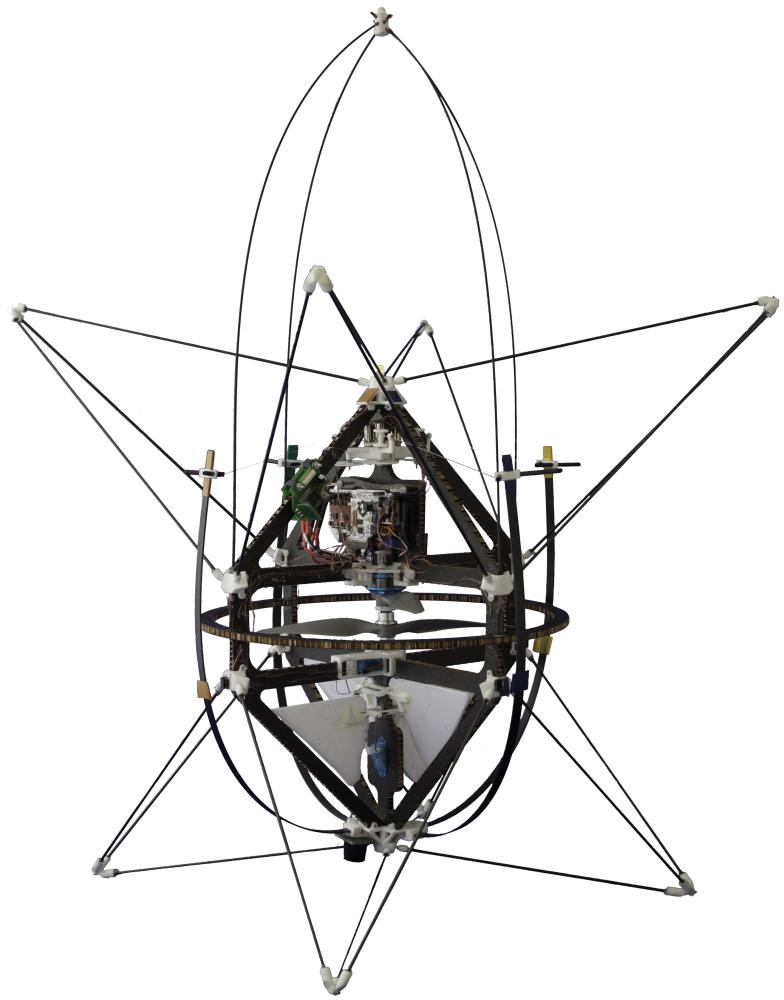
The Airburr, a light-weight flying robot from the Laboratory of Intelligent Systems (my PhD lab) at EPFL, was designed to fly in cluttered environments. Unlike most flying robot, which avoid contact at all cost, the Airburr interacts with its environment to navigate. Just like you might trail your hand along a wall to find your way in the dark, the robot can bounce of walls or follow them without crashing to the ground. In case of a crash, it also has a mechanism to pick itself back up and fly away. I’ve added past videos of the Airburr in action below.

The Airburr can now perch, thanks to a gecko-inspired adhesive pad that is mounted on a mechanism within the structure of the robot. This work was presented last week and ICRA (read the paper here). The gecko pad can be deployed on demand when perching is initiated. Perching allows the robot to power down and save energy, while still providing an aerial perspective that is useful for real-world missions such as search and rescue.

The work was done in collaboration with Mettin Sitti from Carnegie Mellon University, an expert in dry adhesive materials, and was inspired by the hairy feet of geckos. Rather than using claws or sticky substances to climb up walls, geckos use van der Waals forces between the tip of each hair and the surface to cling to. The artificial hairs used on Airburr have a diameter of 40um and a height of 100um with mushroom tips of 80um.

Airburr Crash Recovery

Uprighting Mechanism


tags: , , , ,


Sabine Hauert is President of Robohub and Associate Professor at the Bristol Robotics Laboratory

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence











