
Robohub.org
Introducing H-ROS: the Hardware Robot Operating System
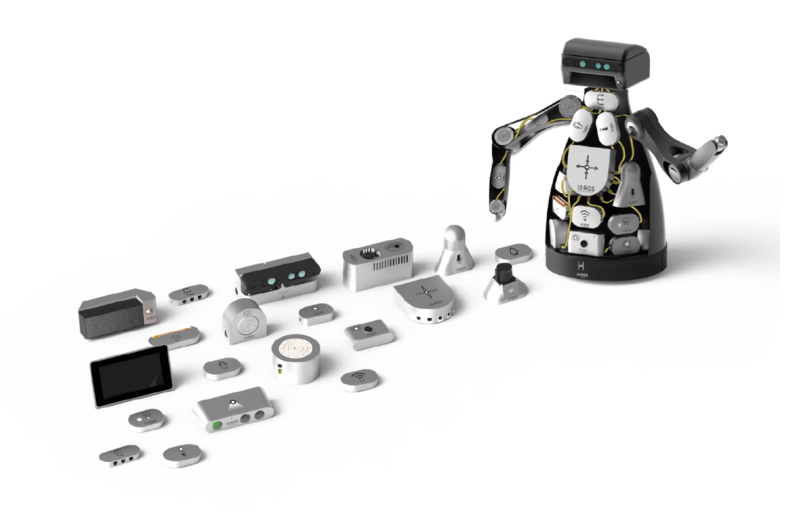
I’m delighted to announce a new game-changing standard for building robot hardware components: H-ROS (the Hardware Robot Operating System). H-ROS provides manufacturers tools for building interoperable robot components that can easily be exchanged or replaced between robots. H-ROS is about supporting a common environment of robot hardware components, where manufacturers comply with standard interfaces built upon the popular Robot Operating System (ROS).
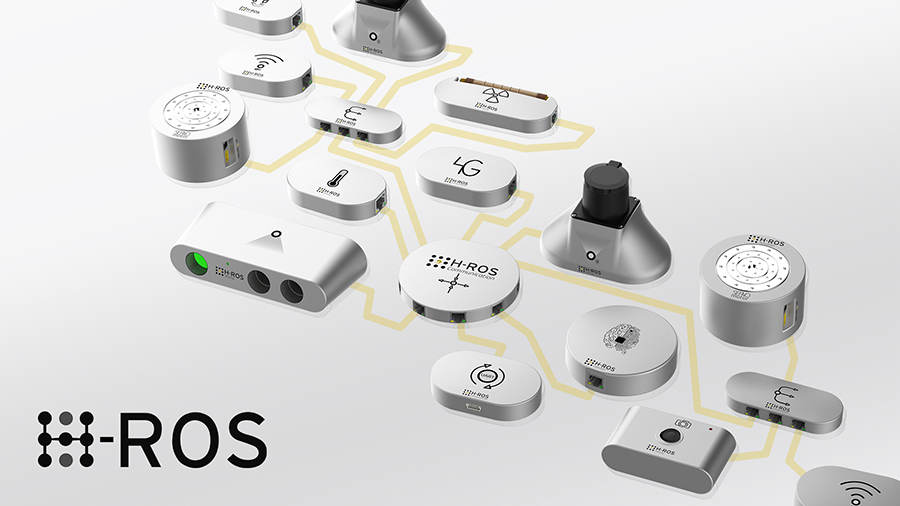 Powered by ROS and built with industry and developers in mind, H-ROS classifies robot components in 5 types: sensing — used to perceive the world; actuation — allowing interaction with the environment; communication — providing a means of interconnection; cognition — the brain of the robot and hybrid; and the components that group together different sub-components under a common interface. These building-block-style parts come as reusable and reconfigurable components, allowing developers to easily upgrade their robots with hardware from different manufacturers, and add new features in seconds.
Motivation and origin:
Building a robot is tricky. Therefore, it makes sense to reuse existing work in an effort to reduce complexity. Unfortunately, nowadays there are few projects, either in industry or academy, that reuse hardware. Robots are generally built by multidisciplinary teams (generally a whole research group or company division), and different engineers get involved in the mechanical, electrical and logical design. Most of the time is spent dealing with the hardware/software interfaces, and little effort is put into behavior development or real-world scenarios.
Existing hardware platforms—although becoming more common—lack extensibility. Examples can be seen in several commercial and industrial robots that hit the market recently, and already include a common software infrastructure (generally the Robot Operating System(ROS)) but lack of a hardware standard.
With H-ROS, building robots will be about placing H-ROS-compatible hardware components together to build new robot configurations. Constructing robots will no longer be restricted to a small elite with high technical skills. It will be extended to the wider majority with a general understanding of the sensing and actuation needed for a particular scenario.
H-ROS was initially funded by the US Defense Advanced Research Projects Agency (DARPA) through the Robotics Fast Track program in 2016 and developed by Erle Robotics.
H-ROS was showcased and presented officially at ROSCon 2016 (October 8th-9th) in Seoul, South Korea, and is now available for selected industry partners and will soon be released for the wider robotics community.
Click here for the official H-ROS website
tags: announcements, research
AUAI is supported by:










