Robohub.org
 

Liatris: looking to change how robots see the world

by
20 October 2015


share this:
Liatris

Fully autonomous robotics could be developed today if objects could tell a robot what they are, their purpose and how to utilize them. Liatris is a new open source project built with ROS. Its objective is to reliably read an object’s pose and identity without relying on vision. It presents an opportunity to rip down the barriers that prevent robotics from being present in our everyday lives.

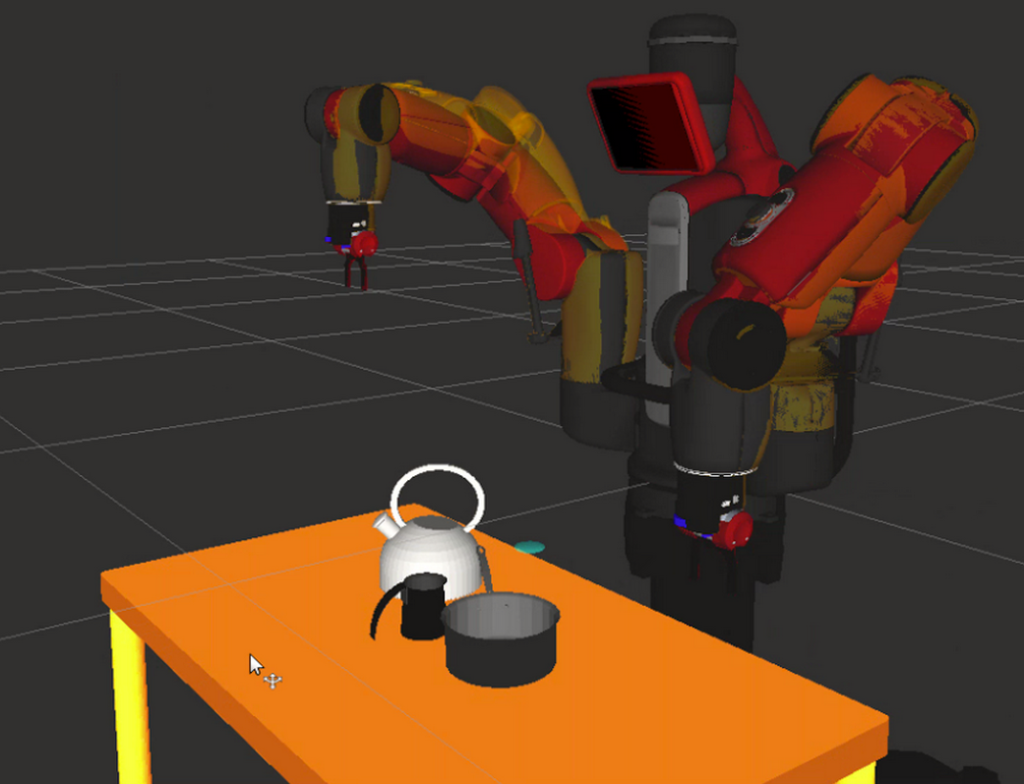
Traditionally, a robot would be required to identify and locate every object in its workspace. Liatris, which is built primarily using ROS, Kivy and Python, instead determines any object’s pose and identity using a touch screen and RFID reader.

The robot in the video is programmed to identify and grasp any object placed on the touch screen, regardless of the object’s shape, size or positioning. It perceives the object by utilizing the CAD model downloaded from Liatris’ API.

This also tells the robot how to grasp an object while avoiding collisions with other objects (thanks to MoveIt).

The result is an accurate 3D perception and mobile manipulation solution. Liatris can even work simultaneously with multiple objects and touch screens.

Learn more at  Liatris.org


tags: , ,


Mark Silliman is currently the CEO at Smartwaiver, an online waiver solution for businesses.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence