Robohub.org
095
From research to industry in the AUV market with David Lane
Today David Lane from Heriot-Watt University in Edinburgh talks about his journey from research to business and back. He talks about how he got started in offshore work and robotics research and how that led him to develop new smarts for existing hardware. David shares his personal view on how the Thunderbirds, diving and the space race contributed to his focus on underwater technology. He also discusses his research on autonomous underwater vehicles, involving software architecture for decision making as well as complex sensors for understanding the world around you and underwater communication.
Further, David shares his experience of starting the company SeeByte, including the important first customer acquisition. In developing a working commercial solution, bridging the gap between where the university stops and industry starts, was an essential component.
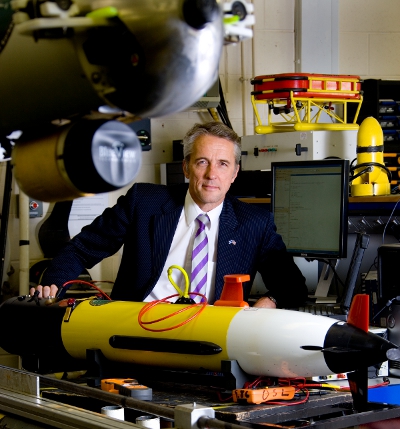
David in the Ocean Systems Laboratory
David Lane
 David Lane graduated in 1980 with a BSc in Electrical and Electronic Engineering from Heriot-Watt University, Edinburgh, and again in 1986 with a PhD in Underwater Robotics. In 1979 he worked offshore in the North Sea as diver/maintainer for British Oceanics Ltd, and from 1980-82 as a Development Engineer at Ferranti Ltd. From 1982 he held a series of research and academic appointments, culminating in a Professorial Chair at Heriot-Watt University in 1998. In 2001 he founded SeeByte Ltd and as CEO until 2010 led the company’s organic evolution from startup to a multi-million dollar organization. He is now at the Ocean Systems Laboratory.
His technical interests are in autonomous systems, sensor processing and underwater robotics. Over a 30 year period he has published widely in the scientific literature, making contributions in underwater vehicle control, servoing, docking and obstacle avoidance. He has developed flexible actuator sensing and control technology for novel robot gripper and biomimetic underwater propulsion applications. In sensor processing, he has led projects applying novel signal processing and data fusion methods using sonar and video systems to marine science and mine countermeasures detection and visualization. He has also led work on robot architecture, autonomous planning and SLAM navigation, culminating in practical automated systems working offshore performing inspection, repair and maintenance.
This interview focuses a lot on the business side of robotics and Davids journey from research to industry and back.
Links:
- Download mp3 (31 MB)
- Subscribe to Robots using iTunes
- Subscribe to Robots using RSS
- David Lane’s personal page
- Heriot-Watt University’s Homepage
- Ocean Systems Laboratory’s Homepage
- Seebyte’s Homepage
tags: podcast