Robohub.org
 

The Year of CoCoRo Video #46/52: JeffShoaling

by
17 November 2015


share this:

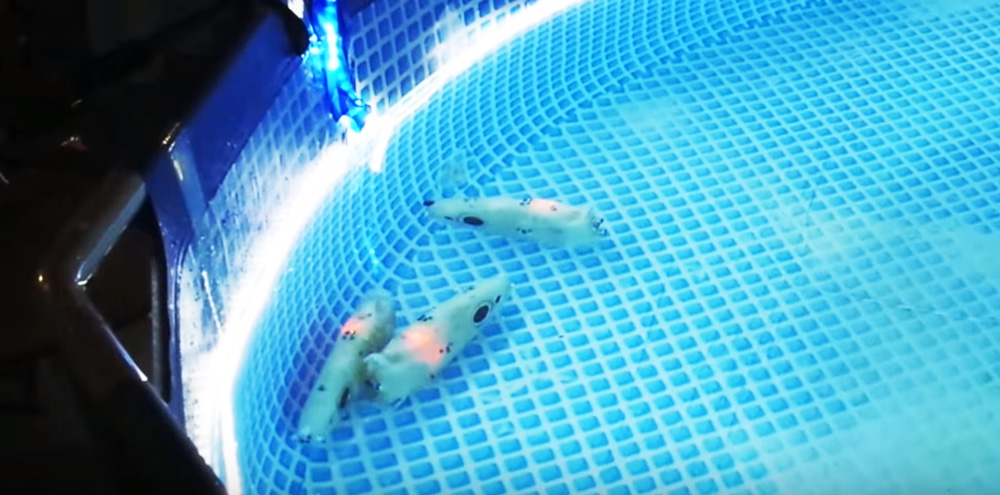
TYOC-46-52--JeffShoaling---YouTubeThe EU-funded Collective Cognitive Robotics (CoCoRo) project has built a swarm of 41 autonomous underwater vehicles (AVs) that show collective cognition. Throughout 2015 – The Year of CoCoRo – we’ll be uploading a new weekly video detailing the latest stage in its development. This week’s video shows an autonomous swarm of underwater robots coordinating their motion to form coherent shoals.

The body shape of Jeff robots is much closer to that of a fish than the Lily robots are. With their slim bodies, Jeff robots can tightly flock together and move in one direction as a group. We implemented a simple blue-light-LED-based algorithm that allows neighboring robots to align to each other. This doesn’t work 100% of the time, but it still works quite often. And when we filmed the little fish that observed our experiments with robots in Livorno harbor (see at beginning of the movie), we observed that the natural fish also did not align 100% of the time. In other words, we came pretty close.

We implemented this code in a very short period of time (hours!) towards the end of the project. With more time and more local neighbor communication, the shoaling can be much improved in future. We hope to be able to further extend this in our follow up project, subCULTron.


tags: , , , , , , ,


Thomas Schmickl is an Associate Professor at Karl-Franzens University, Graz, Austria, and a lecturer at the University for Applied Sciences in St. Pölten, Austria.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.

Robot Talk Episode 168 – Advancing robotics with novel electronics, with Zlatka Stoeva

  30 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Zlatka Stoeva from DZP Technologies about flexible, stretchable and soft printed electronics for dexterous robots.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence