
Robohub.org
podcast
 

Construction with Amorphous Materials with Nils Napp
Wyss Institute         

by
06 September 2013


share this:

In this episode, Sabine Hauert interviews Nils Napp from the Self-organizing Systems Research Group at the Wyss Institute at Harvard University.

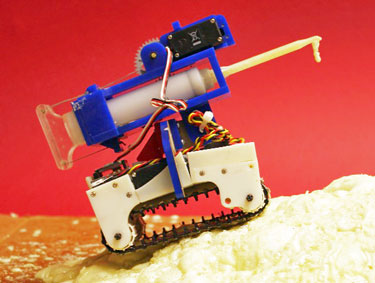
Napp tells us about his project to create robots that can reliably build structures in uncertain, unstructured terrain. Like termites that can build complex structures using shapeless materials like mud, his robots build structures out of foam, toothpicks or bags of sand. As a first example, he’s been working on ramp building in chaotic environments remnant of disaster scenarios. Focus is given to designing algorithms that allow the robot to build up the ramp using only local information and without any preplanning. These features allow his algorithms to be scaled to multiple robots, thereby speeding up the process. Finally, Napp tells us about the challenges he faces when working with such materials, the steps needed to bring these robots out of the lab and tradeoffs with classical construction techniques. He also introduces us to his latest work in synthetic biology.

And here’s an example of another SSR robot using amorphous material by Christian Ahler.

Nils Napp
Nils Napp is a postdoctoral fellow at Radhika Nagpal’s Self-organizing Systems Research Group at the Wyss Institute for Biologically Inspired Engineering at Harvard University. Before coming to Harvard, Nils Napp received his Master and PhD in Electrical Engineering from the University of Washington where he worked at the Klavins lab on Robotic Chemistry and Programmable Parts.

His main research focus is on control strategies for groups of robots and other distributed systems. Ultimately, he hopes to make self-organized systems that like biological systems are able to reliably work in random, unstructured, and fluctuating environments.

Links:


tags: , , ,


Sabine Hauert is President of Robohub and Associate Professor at the Bristol Robotics Laboratory

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence











