
Robohub.org
Philae: A proof of concept for cometary landing
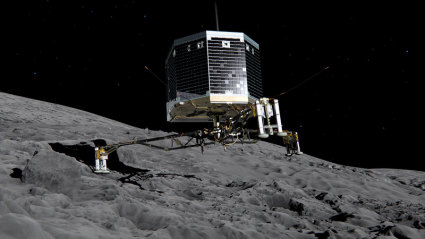 We asked Alan Winfield what the first successful landing on a comet means for the future of space mining. Find out his answer below.
The successful landing of Philae on comet 67P/Churyumov-Gerasimenko this November was an extraordinary achievement and of course demonstrates – despite the immense challenges – that it is possible. The Philae mission was, in a sense, a proof of concept for cometary landing and this, for me, answers the question ‘what does it mean‘.
Of course there is a very large distance between proof of concept and commercial application, so it would be quite wrong to assume that Philae means that space mining (of planets, asteroids or comets) is just around the corner. Undoubtedly the opportunities are immense and – as pressure on Earth’s limited and diminishing resources mounts – there is an inevitability about humankind’s eventual exploitation of off-world resources. But the costs of space mining are literally astronomical, so unthinkable for all but the wealthiest companies or, indeed, nations.
Perhaps multi-national collaborative ventures are a more realistic proposition and – for me – more desirable; the exploitation of the solar system is something I believe should benefit all of humankind, not just a wealthy elite.
But politics aside, there are profoundly difficult technical challenges. You cannot remotely control this kind of operation from Earth, so a very high level of autonomy is required and, as Philae dramatically demonstrated, we need autonomous systems that are able to deal with unknown and unpredictable situations then re-plan and if necessary adapt – in real-time – to deal with these exigencies. The development of highly adaptive, resilient, self-repairing – even self-evolving – autonomous systems is still in its infancy. These remain fundamental challenges for robotics and AI research. But even if and when they are solved there will be huge engineering challenges, not least of which is how to return the mined materials to Earth.
Bearing in mind that to date only a few hundred kg of moon rock have been successfully returned* and Mars sample-return missions are still at the planning stage, we have a very long way to go before we can contemplate returning sufficient quantities to justify the costs of mining them.
*and possibly a few grains of dust from Japanese asteroid probe Hayabusa.
For other views on the Philae touchdown and the future of space mining and exploration, see:
- Touchdown! Rosetta’s Philae makes first ever landing on a comet
- One giant leap: Rosetta and the space mining frontier
- Space mining: Robots in the final frontier
See all the latest robotics news on Robohub, or sign up for our weekly newsletter.
tags: Alan Winfield, ESA, EU perspectives, exploration & mining, opinion, Philae, Rosetta, space
AUAI is supported by:










