Robohub.org
 

Research Group from University of Zurich wins KUKA Innovation Award

by
10 June 2014


share this:
Kuka-award
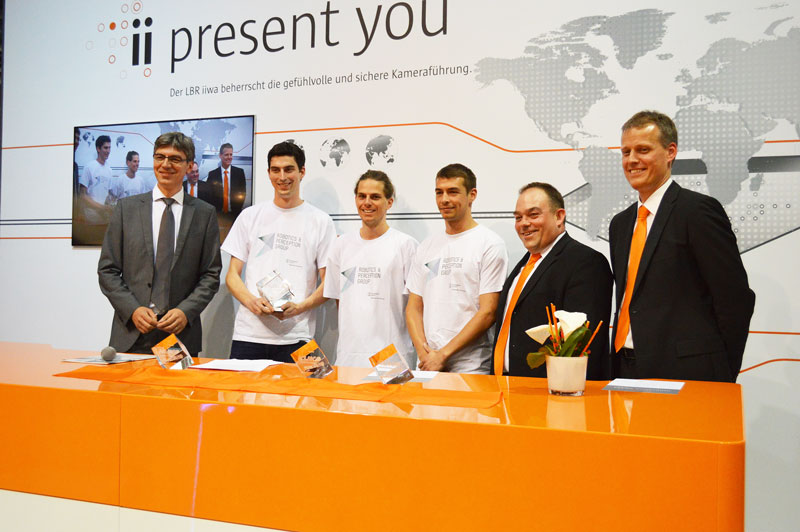
The team collect their award at the Automatica fair in Munich, June 2014.

Four researchers from Davide Scaramuzza’s Robotics and Perception Group at the University of Zurich, Switzerland, have won the prestigious KUKA Innovation Award (20.000 EUR) for their project “Collaboration of Flying and Ground Robots for Search-And-Rescue Missions” at the AUTOMATICA trade fair in Munich.

The ongoing project is part of the “Rescue Scenario” of NCCR Robotics, where researchers across Switzerland work together to develop robots that can be used to make disaster relief efforts safer and more efficient. This specific element of the Rescue Scenario involves teams of flying robots working together with ground robots. The idea behind the project is that, in a cluttered environment after a disaster, it may be too dangerous for human rescuers to enter a building, and so robots may be utilized. However, in such environments both flying and ground robots suffer from limitations: by working together, the flying robots can be used as the eye for the ground robot.

For the competition last week, the team presented the collaboration of a quadrotor and a KUKA youBot in a mock-up disaster scenario. The quadrotor is first sent to make a map of the scene, i.e., detecting obstacles and people who need help. Then, it commands the youBot to these people to deliver a first-aid package. From the air, it can tell the youBot where to go and which obstacles to remove on the way.

Have a look at the demo showed at AUTOMATICA!


tags: , , , , , ,


NCCR Robotics

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence