Robohub.org
ep.

299

podcast
 

On the Novelty Effect in Human-Robot Interaction with Catharina Vesterager Smedegaard

by
09 December 2019


share this:


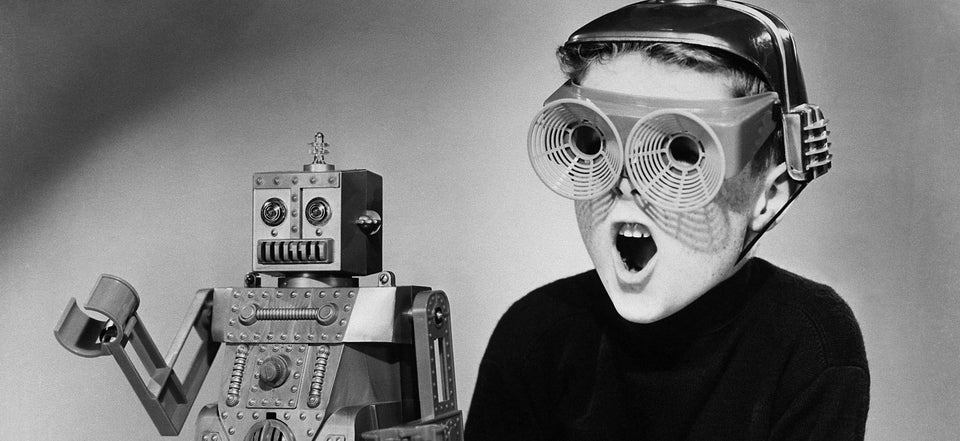
From Robert the Robot, 1950s toy ad

In this episode, we take a closer look at the effect of novelty in human-robot interaction. Novelty is the quality of being new or unusual.

The typical view is that while something is new, or “a novelty”, it will initially make us behave differently than we would normally. But over time, as the novelty wears off, we will likely return to our regular behaviors. For example, a new robot may cause a person to behave differently initially, as its introduced into the person’s life, but after some time, the robot won’t be as exciting, novel and motivating, and the person might return to their previous behavioral patterns, interacting less with the robot.

To find out more about the concept of novelty in human-robot interactions, our interviewer Audrow caught up with Catharina Vesterager Smedegaard, a PhD-student at Aarhus University in Denmark, whose field of study is Philosophy.

Catharina sees novelty differently to how we typically see it. She thinks of it as projecting what we don’t know onto what we already know, which has implications for how human-robot interactions are designed and researched. She also speaks about her experience in philosophy more generally, and gives us advice on philosophical thinking.

Catharina Vesterager Smedegaard
Catharina Vesterager Smedegaard started as a PhD-student the 1st of December 2017. She has a BA and MA in philosophy. In autumn 2015, Catharina interned at the research group PENSOR (the present RUR), where she first became interested in Social Robotics and formed the idea for her MA thesis.

Links


tags: , ,


Audrow Nash is a Software Engineer at Open Robotics and the host of the Sense Think Act Podcast

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.

Robot Talk Episode 168 – Advancing robotics with novel electronics, with Zlatka Stoeva

  30 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Zlatka Stoeva from DZP Technologies about flexible, stretchable and soft printed electronics for dexterous robots.

Competing in RoboCup@Home and winning the 2026 best paper award: an interview with Raphael Memmesheimer

and   28 Oct 2026
Hear more about Raphael's research and his involvement in the RoboCup@Home league.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence