Robohub.org
ep.

214

podcast
 

Project Ngulia: From Phone to Drone with Fredrik Gustafsson

by
06 August 2016


share this:


Black-rhino-Yoki-WC

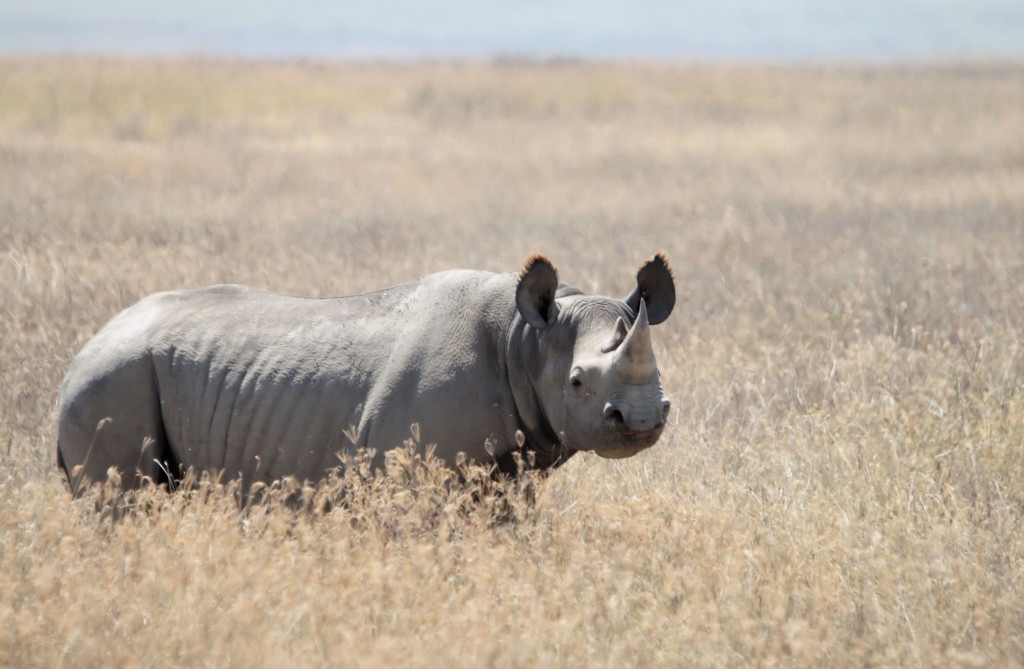
In this episode, Audrow Nash interviews Fredrik Gustafsson, Professor in Sensor Informatics at Department of Electrical Engineering in Linköping University, about an initiative to reduce poaching in a rhino sanctuary in Ngulia, Kenya. Gustafsson discusses how he first became involved in this project, how he has worked with the rangers to develop solutions, and the future of this work.


Fredrik Gustafsson
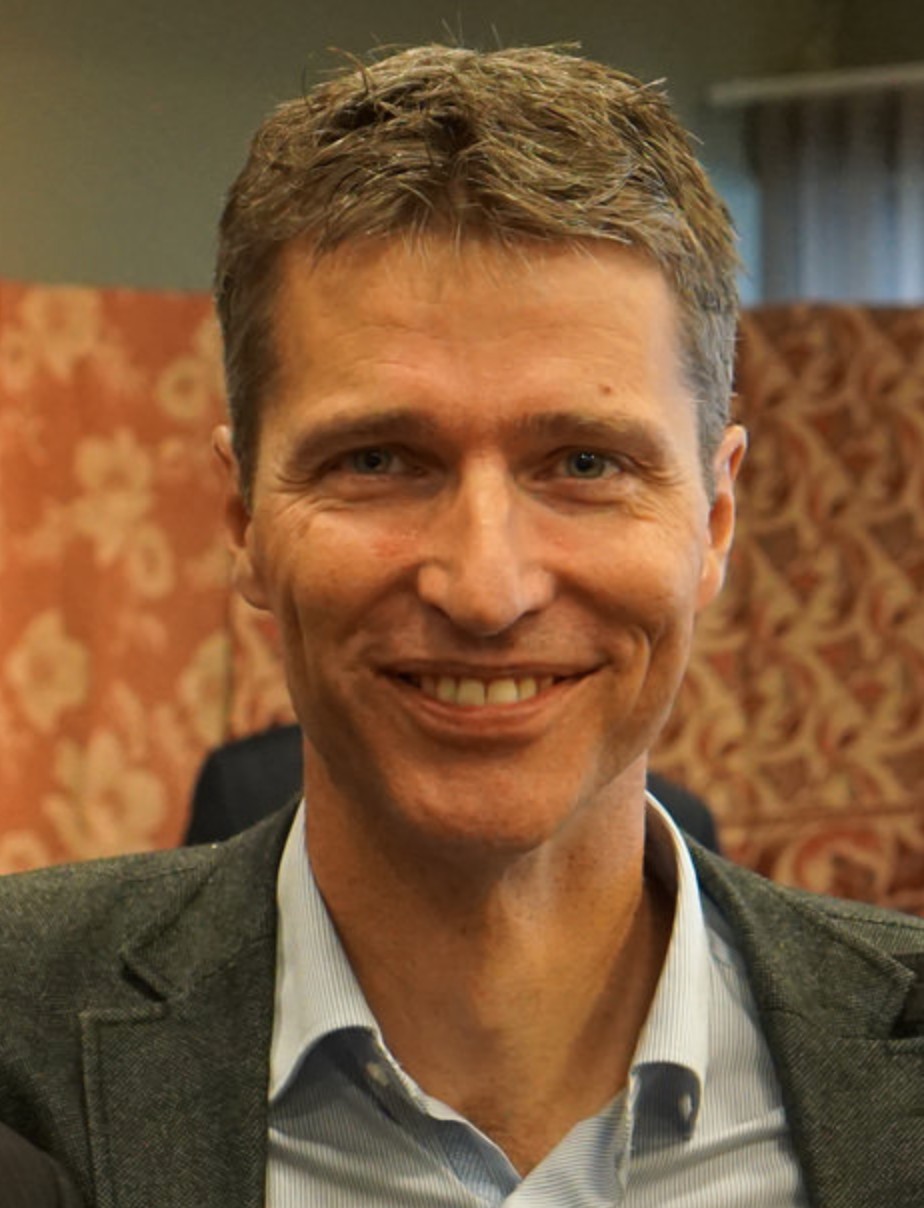
FredrikGustafssonFredrik Gustafsson is professor in Sensor Informatics at the Department of Electrical Engineering, Linköping University, since 2005. He received the M.Sc. degree in electrical engineering 1988 and the Ph.D. degree in Automatic Control, 1992, both from Linköping University. His research interests are in stochastic signal processing, adaptive filtering and change detection, with applications to communication, vehicular, airborne, and audio systems. His work in the sensor fusion area involves design and implementation of nonlinear filtering algorithms for localization, navigation and tracking of all kind of platforms, including cars, aircraft, spacecraft, UAV’s, surface and underwater vessels, cell phones and film cameras for augmented reality. He is a co-founder of the companies NIRA Dynamics (automotive safety, including tire pressure monitoring systems found in more than 20 million, here), Softube (plug-ins for music studios and software solutions for Marshall and Fender), and Senionlab (leading manufacturer of indoor navigation solutions for sm, here).

Links:


tags: , , , , , , , , , , , , ,


Audrow Nash is a Software Engineer at Open Robotics and the host of the Sense Think Act Podcast

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 171 – Programming robot behaviour, with Sebastian Castro

  20 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Sebastian Castro about developing open-source software for robot task planning and behaviour.

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence