Robohub.org
podcast
 

Origami Robots with Nick Kohut

Dash Robotics         

by
20 September 2013


share this:

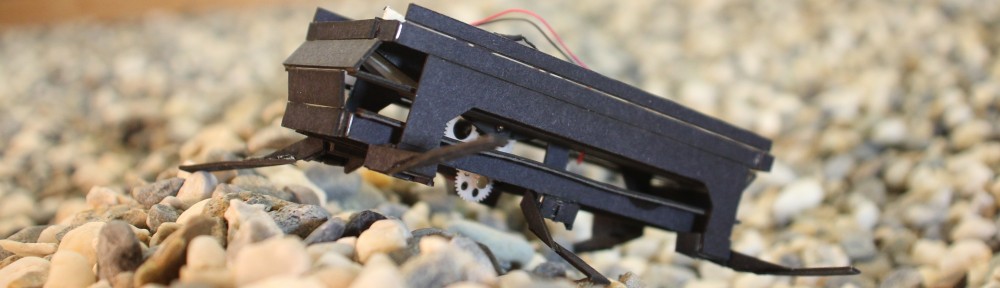
In this episode Matthew Schroyer speaks with Nick Kohut, CEO of Dash Robotics, about their foldable hexapod robot and the ongoing crowdfunding campaign to get them into the hands of budding engineers, kids and hobbyists.

Dash is the result of years of research in fast prototyping of bioinspired robots at Ron Fearing’s Biomimetic Millisystems Lab at UC Berkeley (see Fearing Podcast or Hoover Podcast). The palm-sized origami robot is now available for the general public to build and program. The robot takes inspiration from insect locomotion by using compliant and light weight hardware to drive over difficult terrain without using any complex controllers (see Bob Full podcast). You can check out their Dragon crowdfunding campaign for a chance to get one of the first 1000 robots. The campaign ends on October 2nd.

Nick Kohut
Nick Kohut is the co-founder and CEO of Dash Robotics. He is also a postdoc at Stanford University in Mark Cutkosky’s Biomimetics and Dextrous Manipulation Laboratory, working on a variable stiffness suspension element for humanoid robotics. He received his Ph.D. in Mechanical Engineering at the University of California, Berkeley, in Ron Fearing’s Biomimetic Millisystems Lab, developing small legged robots. His research focused on the development of an active tail to enable high speed turning. In the past, he also did research on centimeter scale robots, and using GPS and traffic information to improve fuel economy.

Links:


tags: , , , , , ,


Matthew Schroyer is a drone and data journalist based in Urbana, Illinois.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 171 – Programming robot behaviour, with Sebastian Castro

  20 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Sebastian Castro about developing open-source software for robot task planning and behaviour.

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence